Project 01
Differential Wrist for Robot
- Problem
- The team needed a differential wrist design that could integrate with other subsystems and serve as a reference for future designs.
- Solution
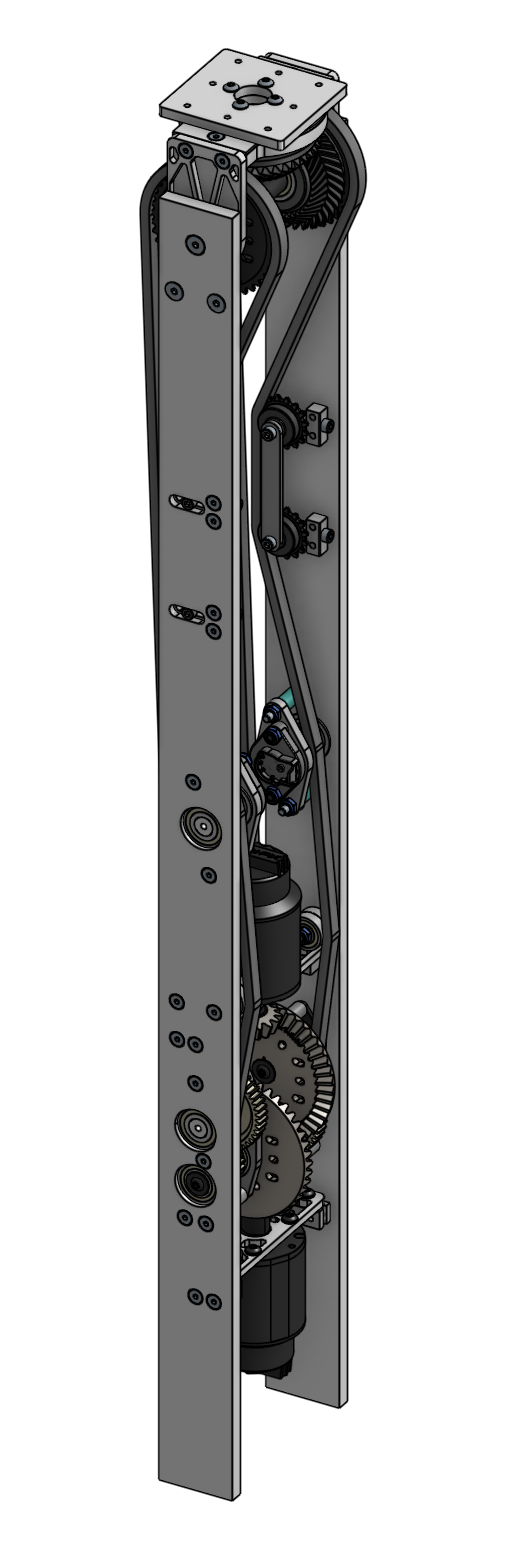
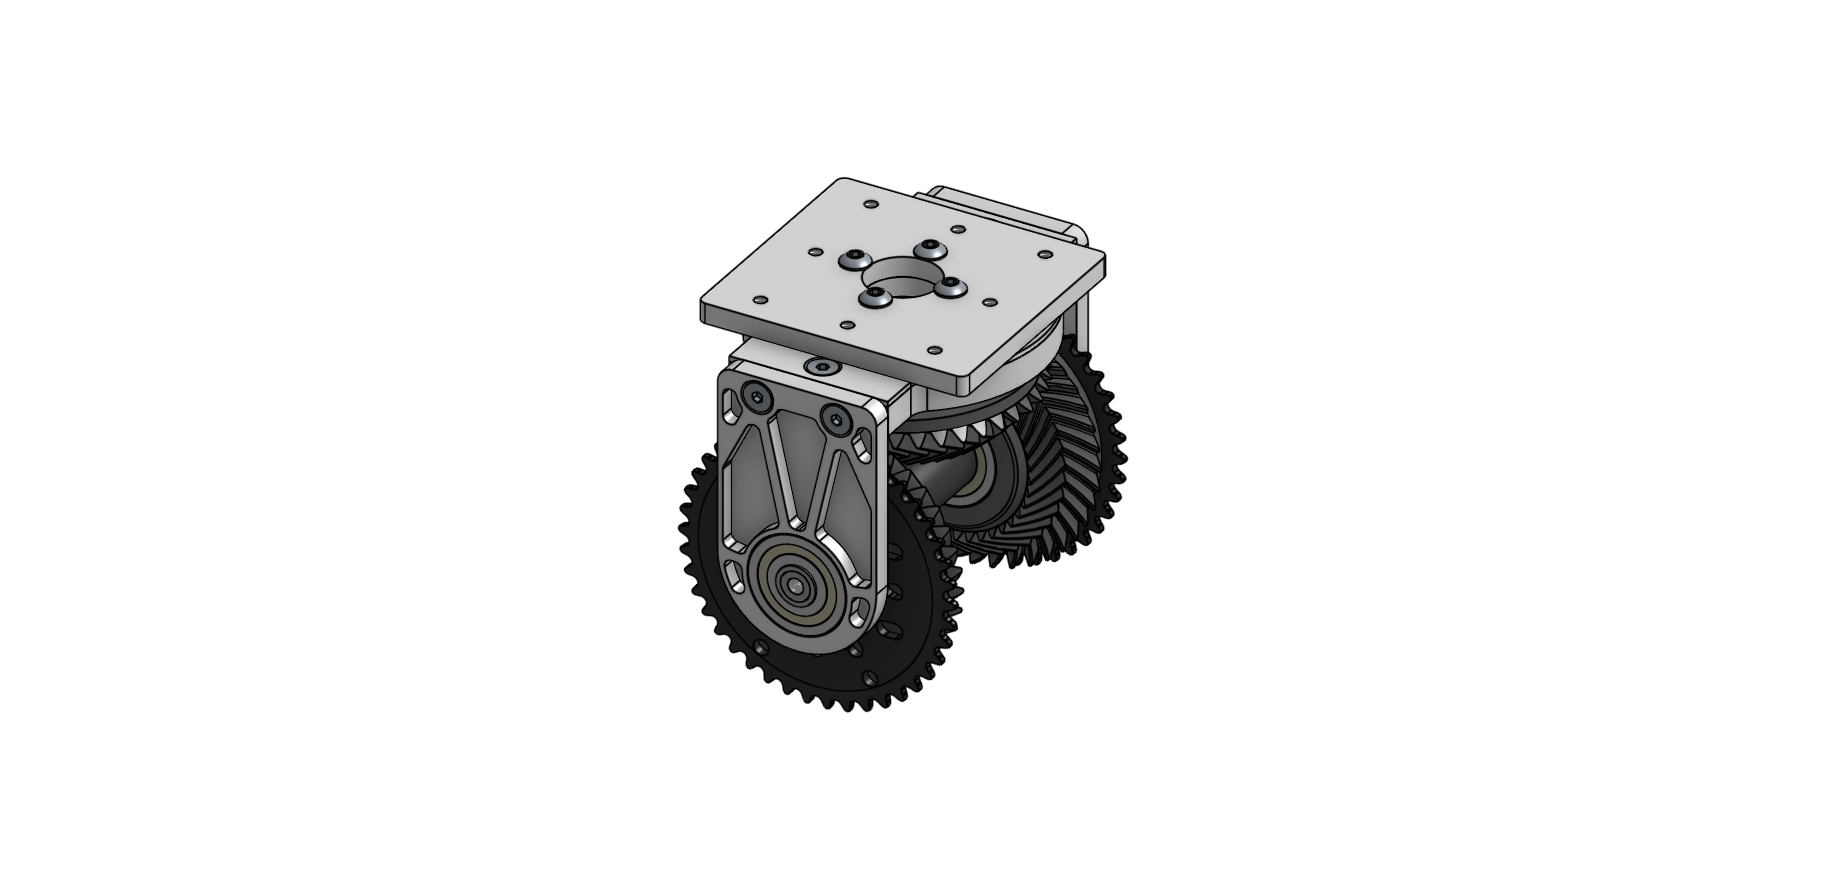
- Designed a differential wrist mechanism with two degrees of freedom and rotation. Used X-contact bearings and a solid shaft for better reliability, even though the team initially wanted regular bearings and hex shafts.
- Status
- Manufacturing pending.
Loading 3D model...
Preparing interactive CAD geometry.
Preparing model...
Assembly Views
The full assembly shows the wrist packaging, while the detail view highlights the differential gearing.